Autonomous racing: models and data
Controller simulation, dataset qualification and an upstream loader correction.
Policy interfaces and synthetic loader checks
All 15 evaluation policies passed the directed synthetic interface comparisons. A candidate terminal-filter correction matched an independent oracle on 16,380 synthetic dtype cases; the original helper failed 4,094.
results and contributions
| Policy interfaces checked | 15 on directed synthetic inputs |
|---|---|
| Candidate correction / oracle agreement | 16,380 of 16,380 synthetic dtype cases |
| Original helper failures | 4,094 on the same finite domain |
figures and hardware
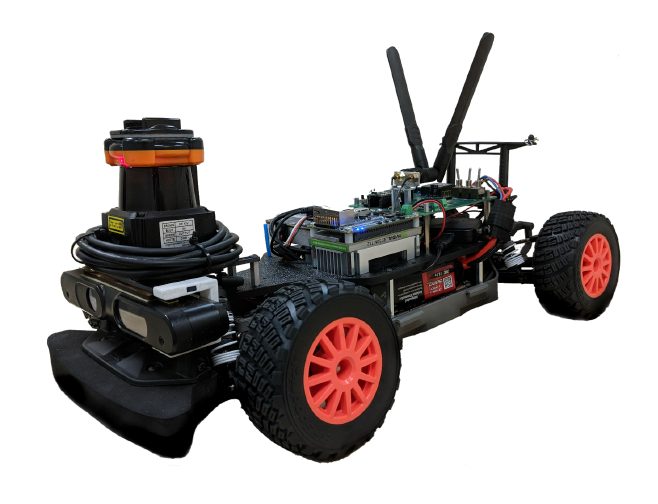
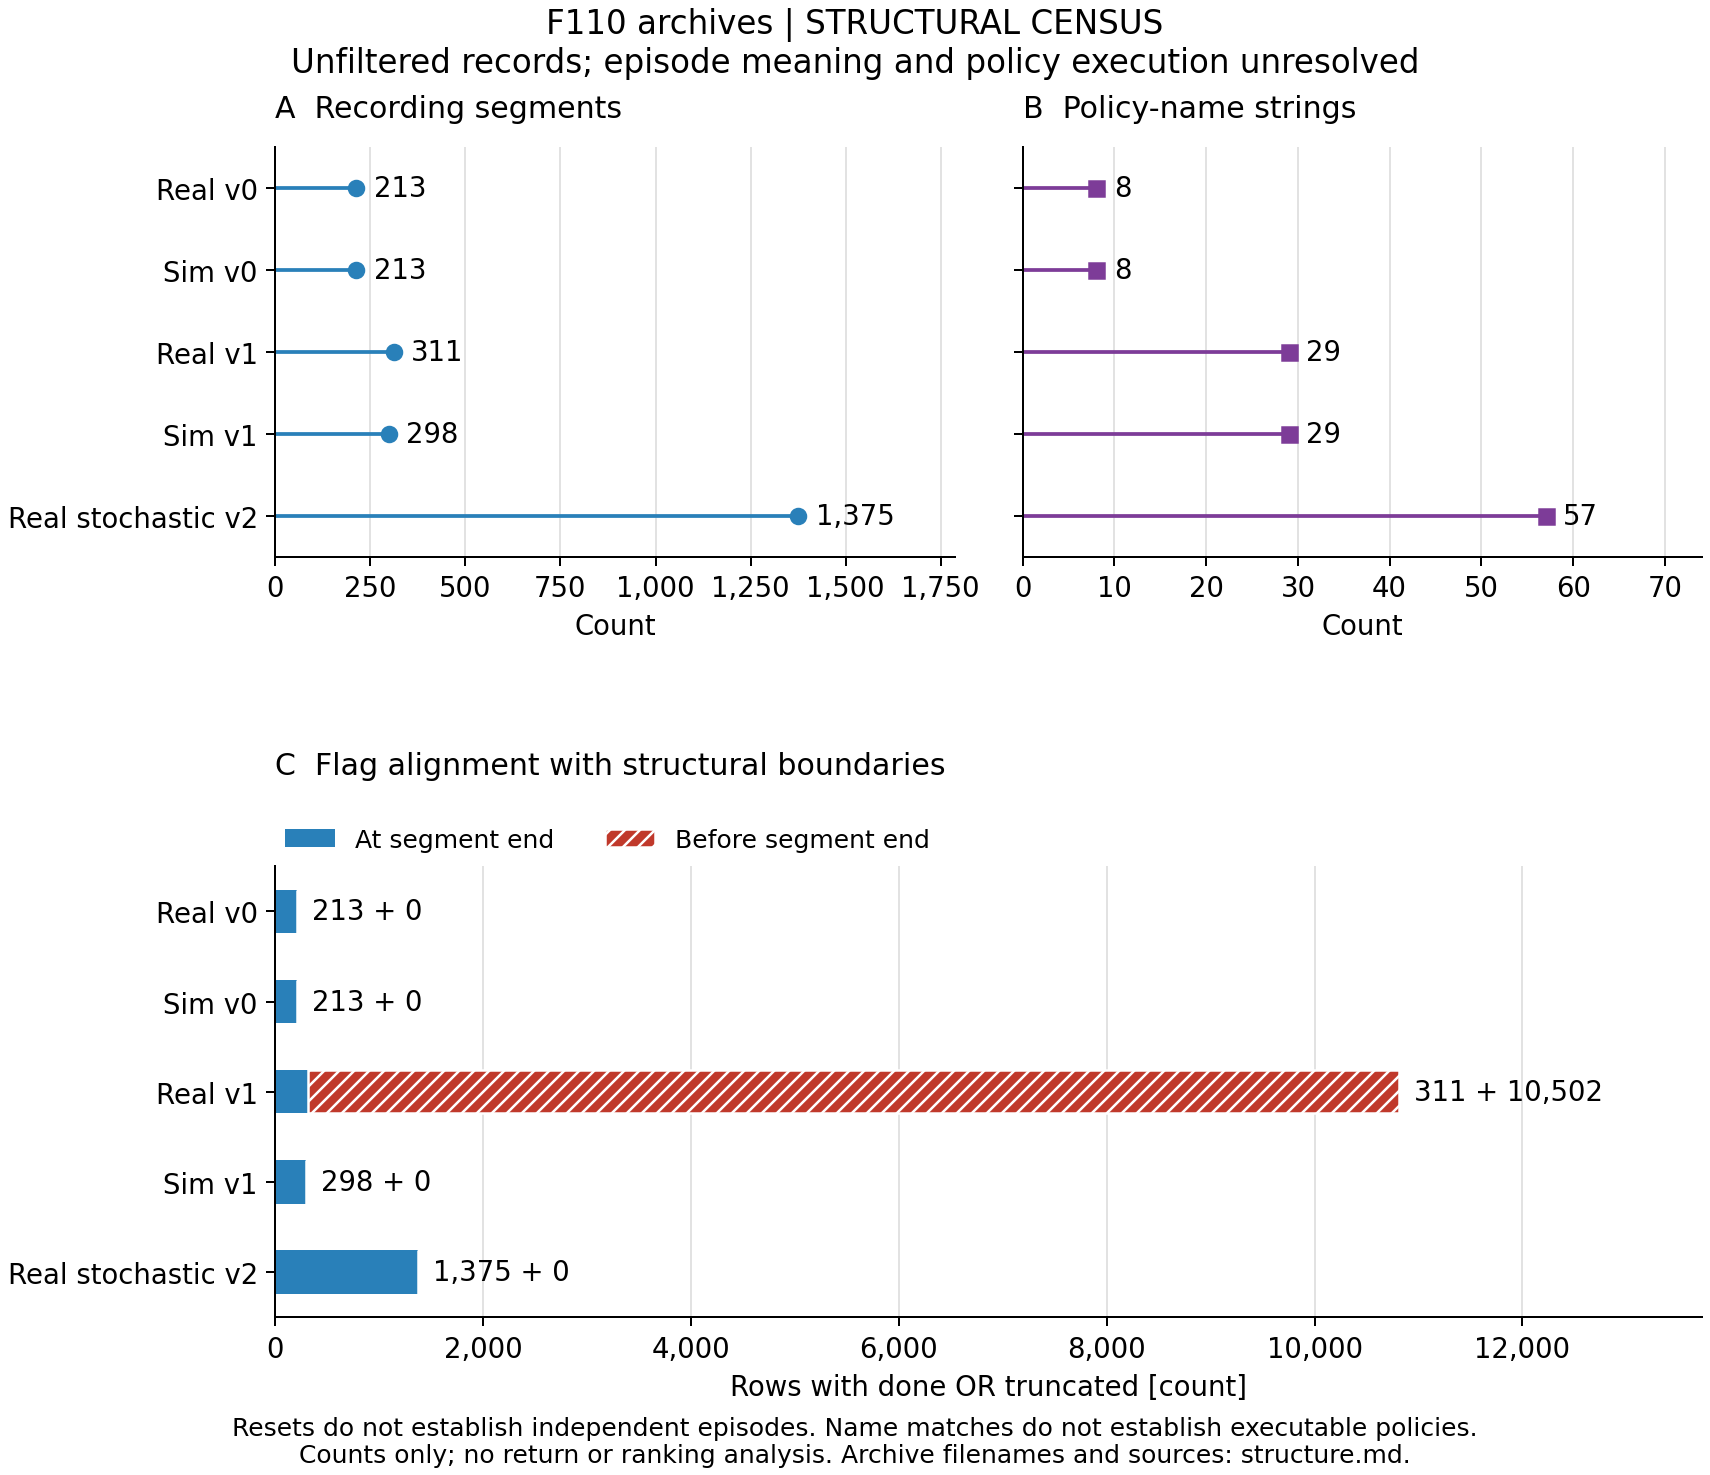
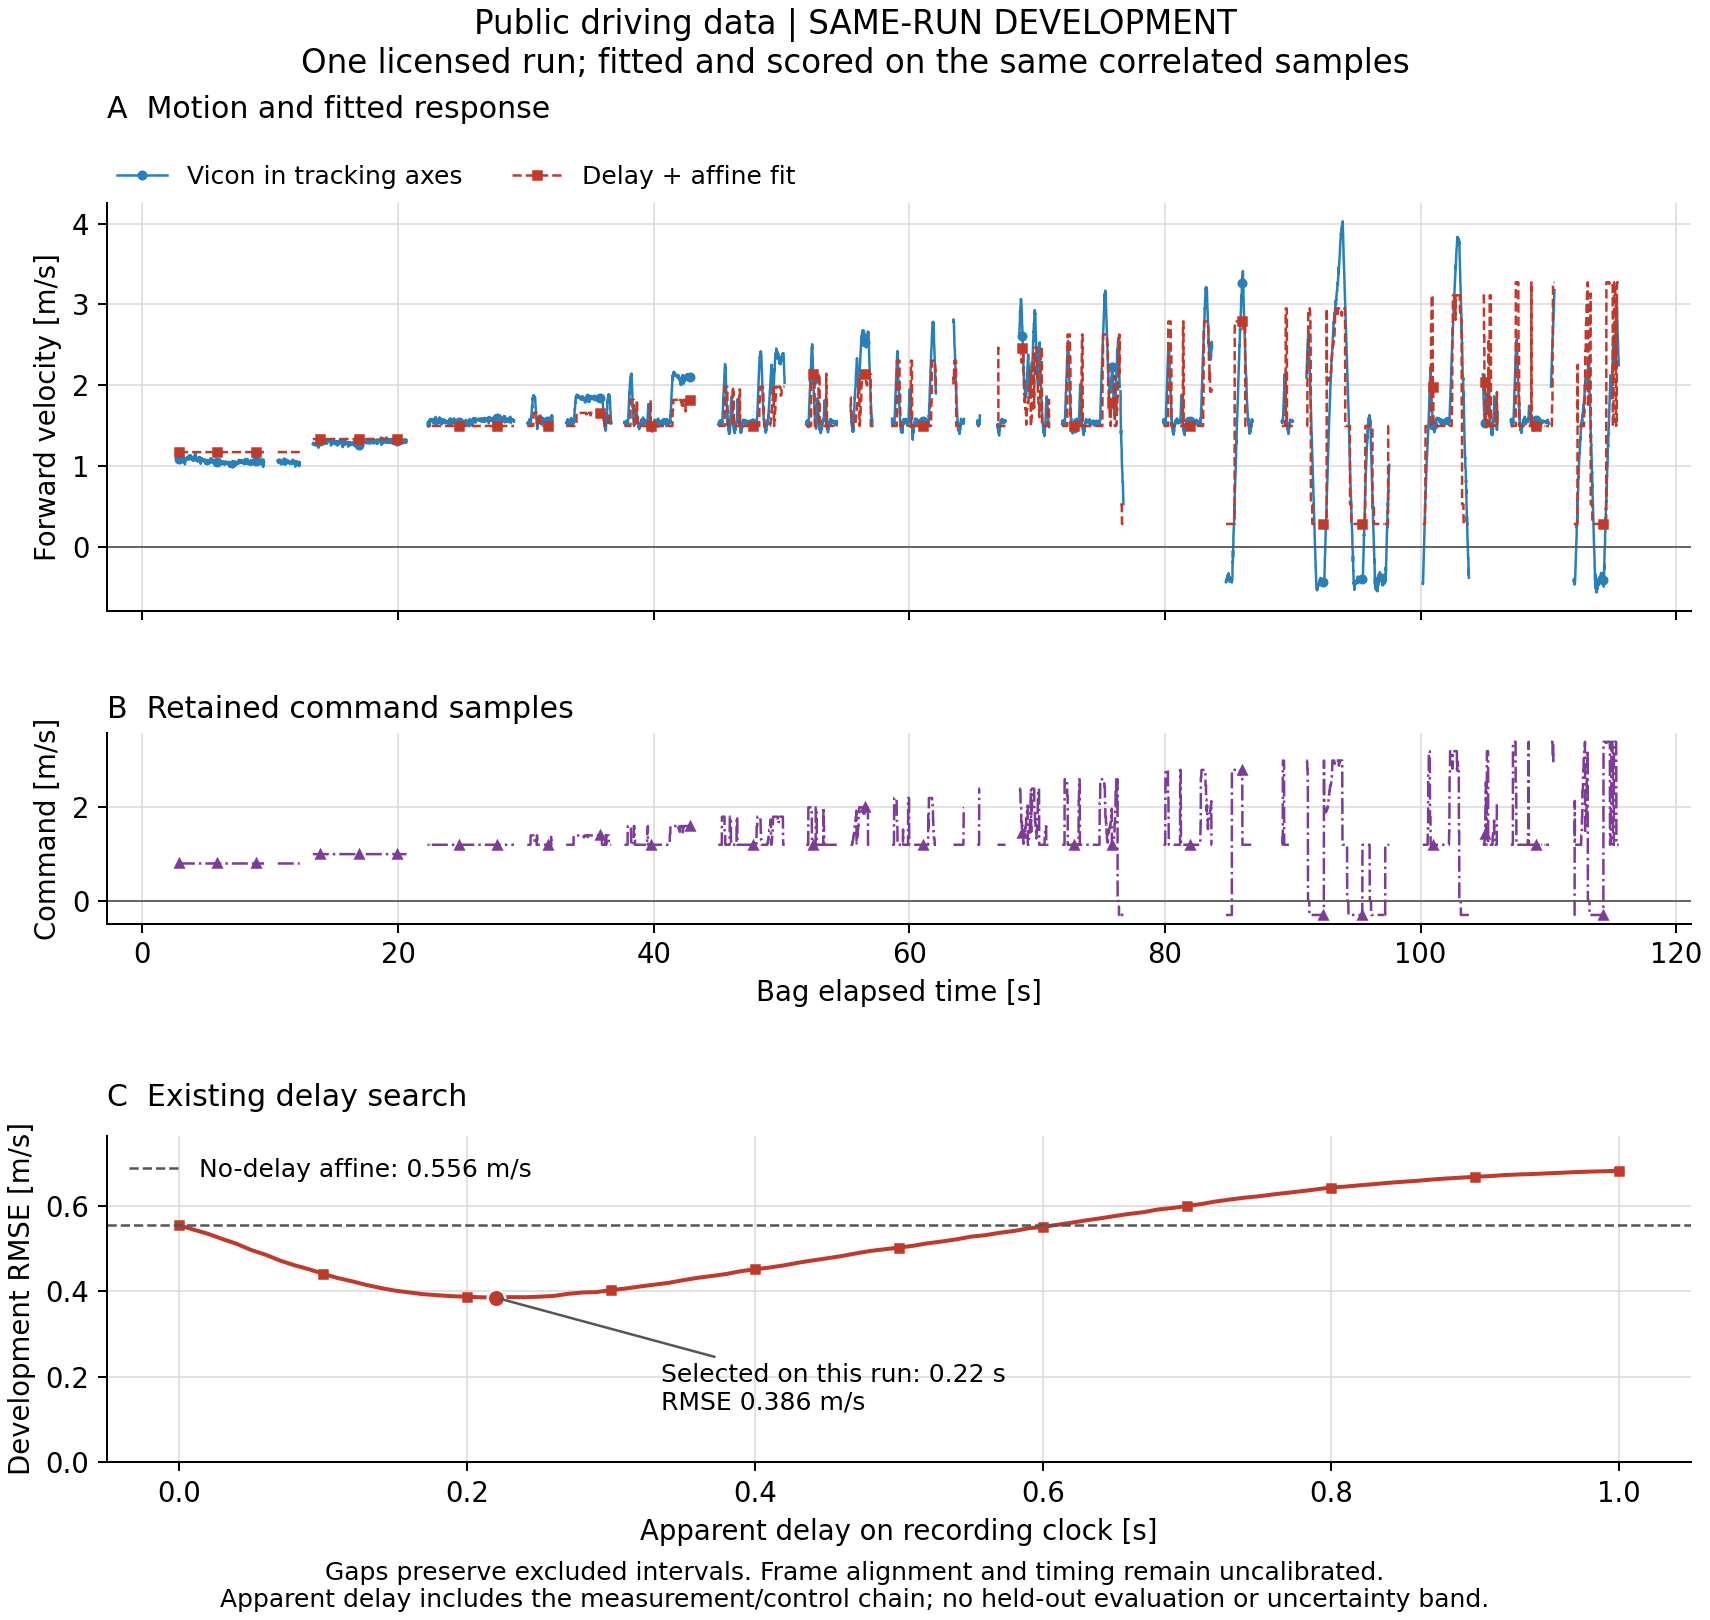
Open any image at full size. Source links identify the retained revision.
design evolution
The design and analysis steps that produced the current work.
| Work | Engineering question | Approach | Outcome |
|---|---|---|---|
| Simulator controllers | Identification used telemetry generated by the same model being fitted. | Retain it as a simulation consistency exercise. | Implemented pure pursuit, LQR and MPC for simulator comparisons. |
| LiDAR mount | A 285.5 Hz mode is crossed by motor shaft order near 8.3 m/s. | Reopen the mounting requirement. | Calculated the shaft-order crossing near 8.3 m/s, identifying a limitation of the original 200 Hz design criterion. |
methods and scope
These are source-code and synthetic-interface results. The candidate correction has not been adopted on archives. Corrected ZIP qualification, reuse terms and the intended simulator revision precede empirical controller rankings. Historical archive figures retain their original pins and do not describe a fresh census of the corrected releases.
project record
| Evidence | Policy interfaces and synthetic loader checks |
|---|---|
| Status | In Progress |
| Timeline | 2026 |
| Role | Archive qualification, command-response analysis and retained simulation tooling |
| Tools | Python, NumPy, F110 datasets, ROS 2, CalculiX |