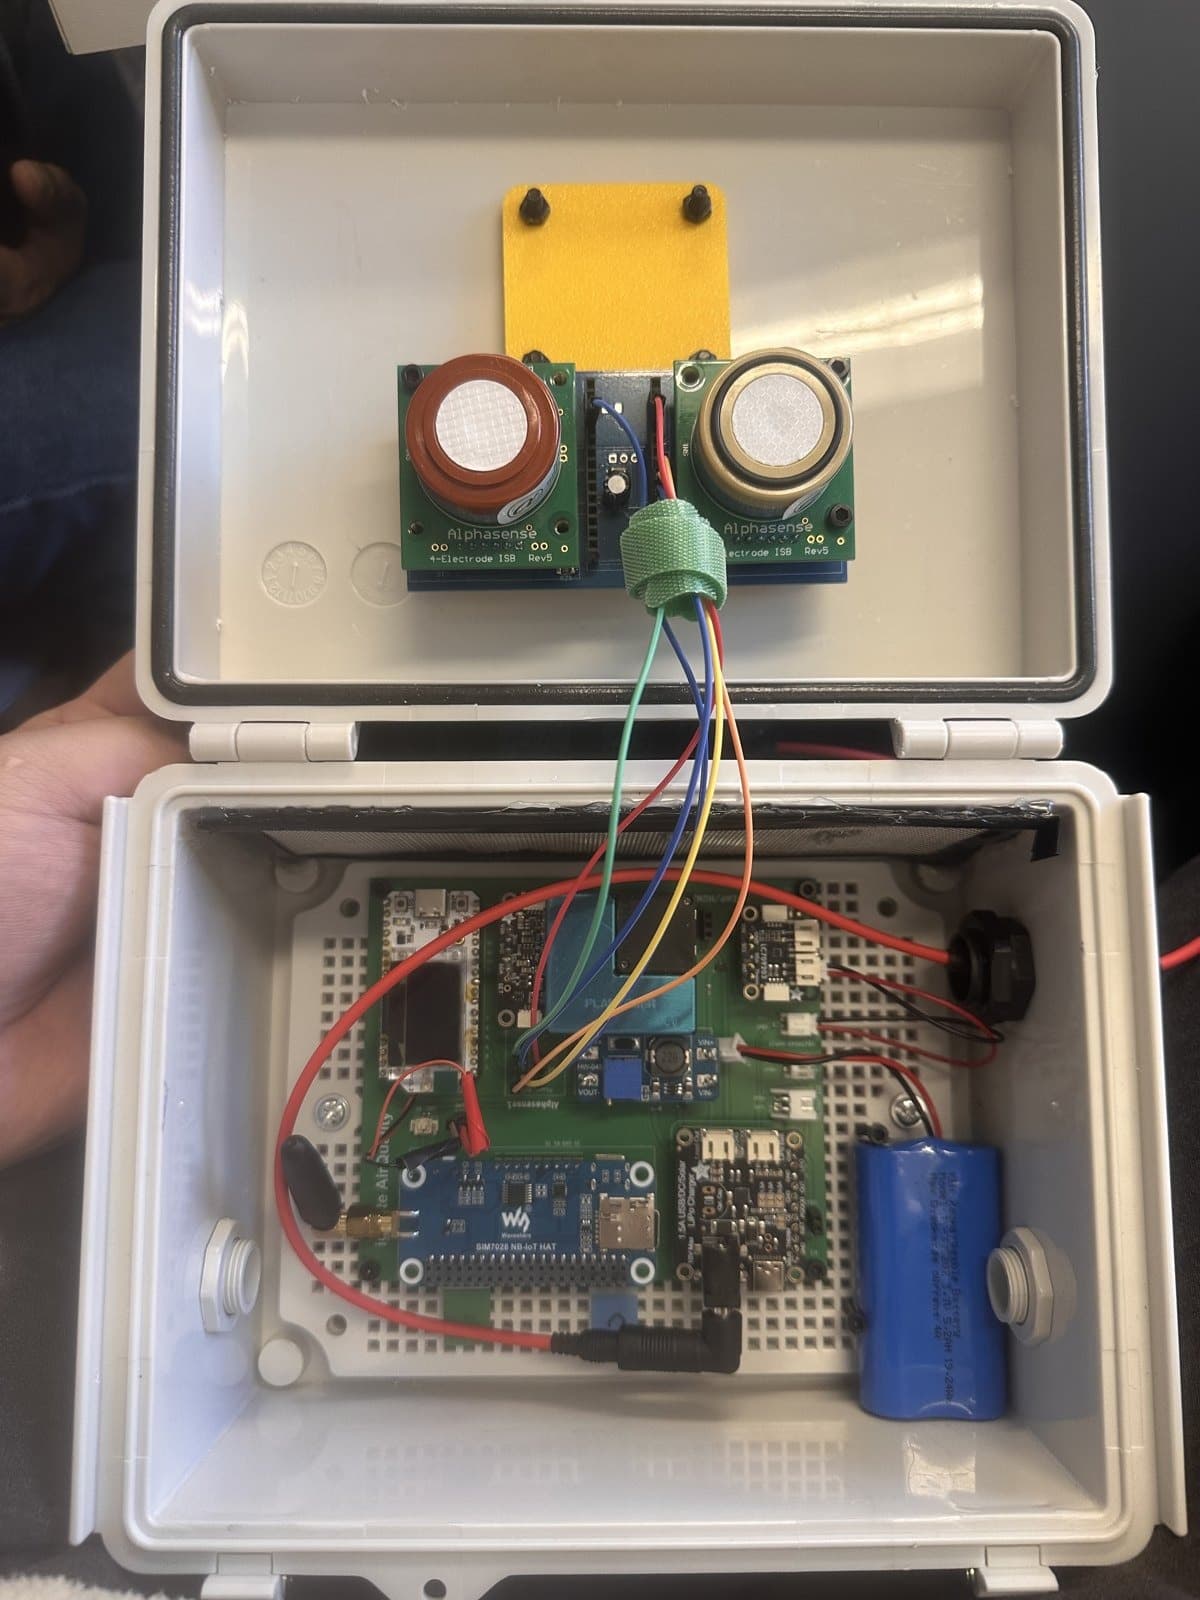
CUSP air-quality nodes: prototype to Queens College
Designed four printed enclosures, reduced housing material cost from $70 to $24, and assembled a new sensor node for Queens College.
500ft/sensor-enclosure-bias-prediction
Hardware I have built, software I have developed, and the analysis behind each project. Explore the prototypes, results and design iterations.
Designed four printed enclosures, reduced housing material cost from $70 to $24, and assembled a new sensor node for Queens College.
500ft/sensor-enclosure-bias-prediction
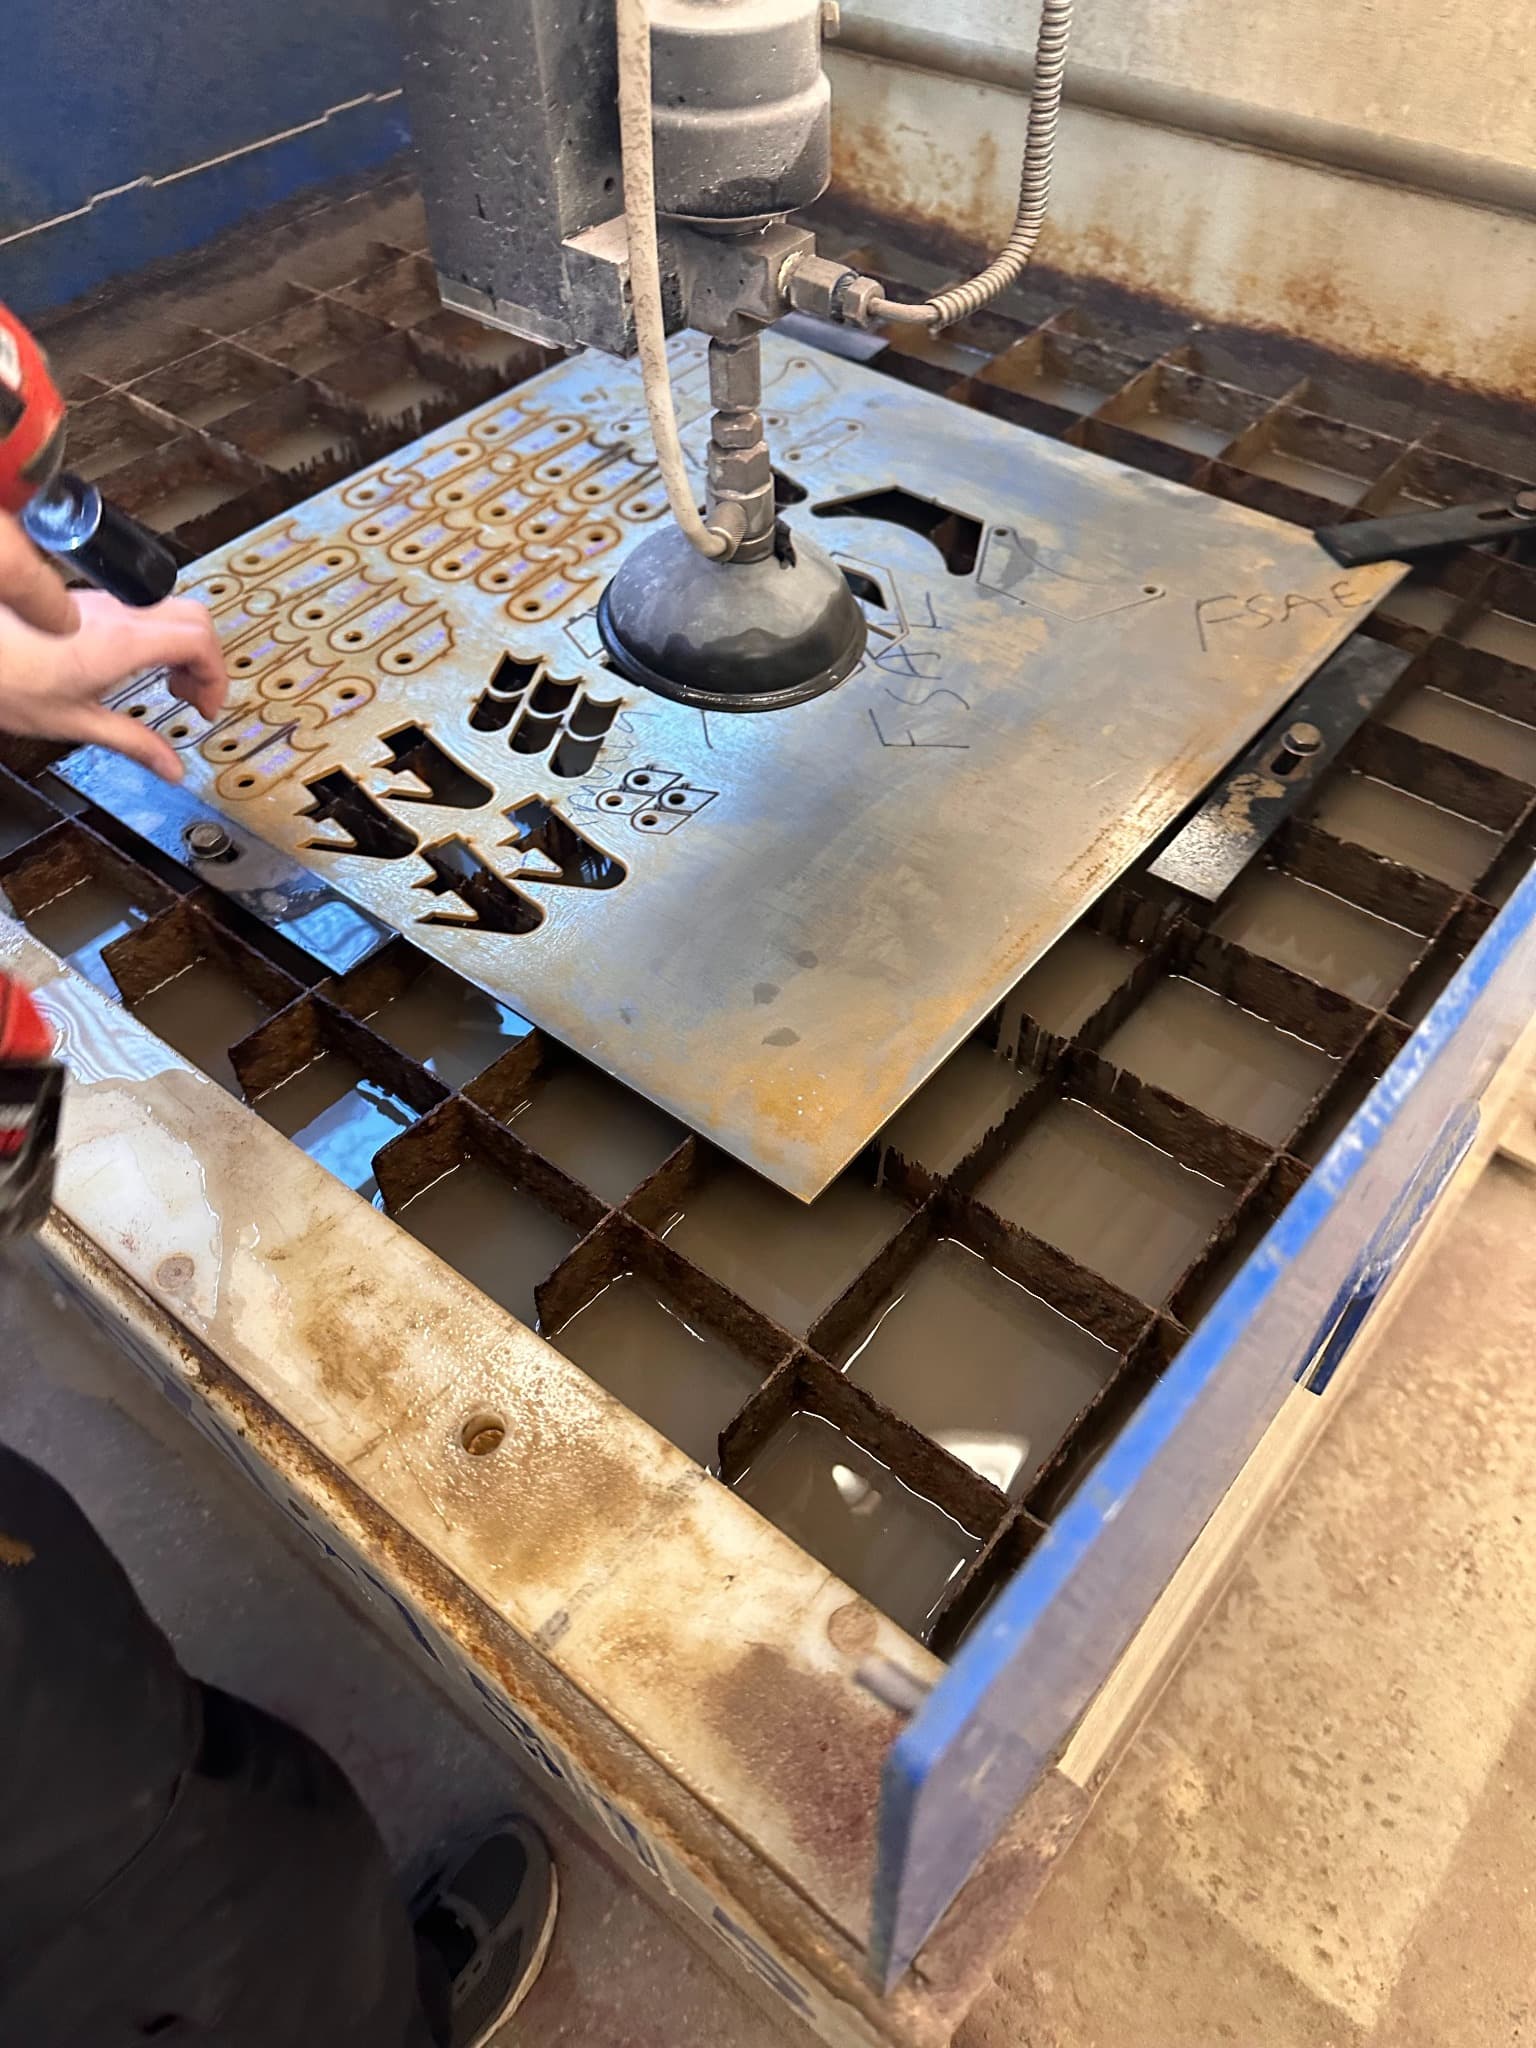
Designed three printed tube-fit fixtures and prepared 32 waterjet-cut steel tabs for suspension and steering fabrication.
500ft/fsae-fixtures
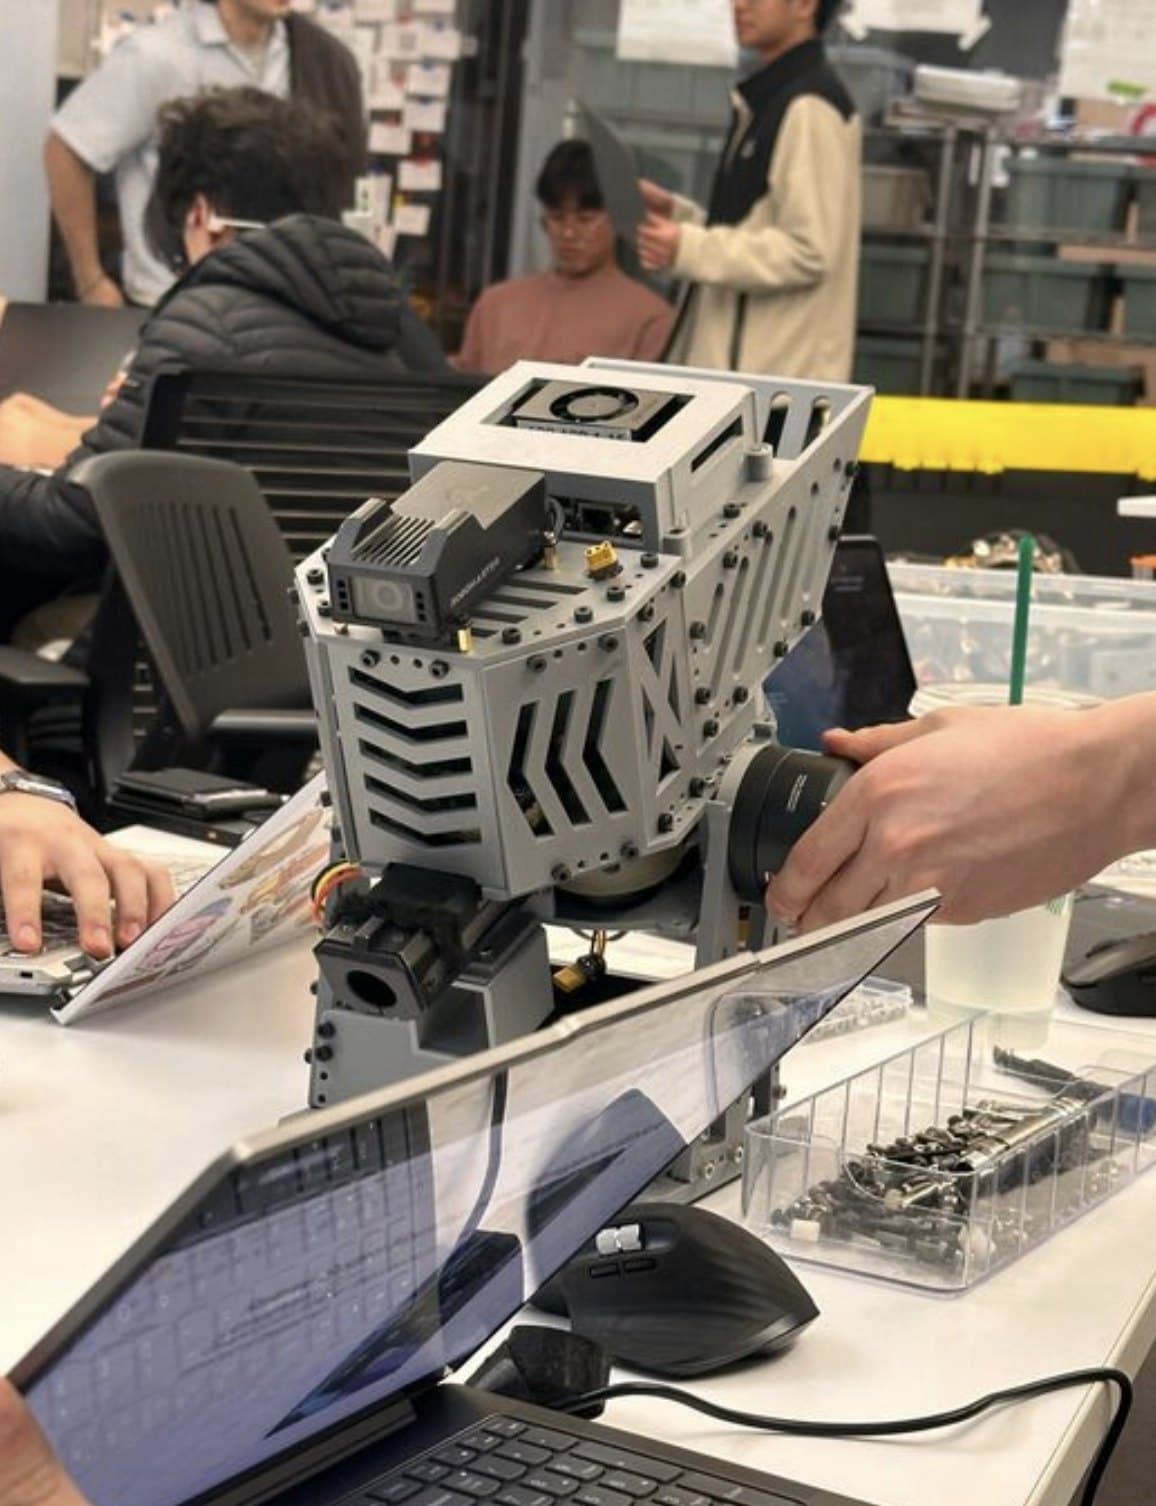
Launcher packaging for a RoboMaster gimbal: a printed flywheel, supercapacitor shell, and armor fitted around a 20.5 mm feed path.
500ft/robomaster-gimbal
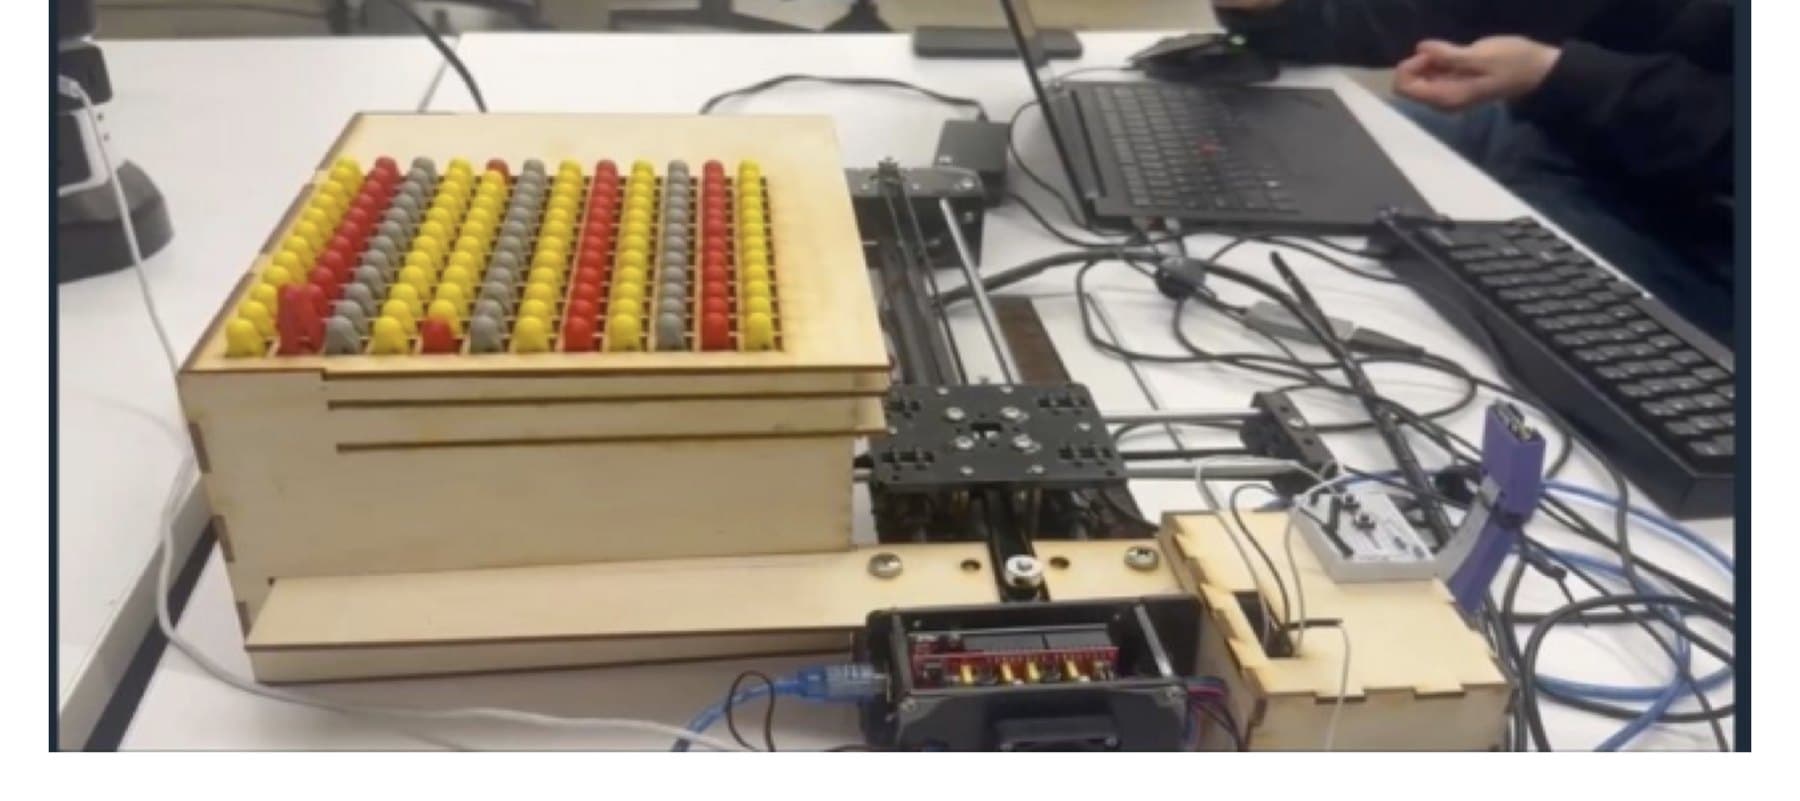
A 12 x 12 tactile pin array that converts a climbing-route image into a raised pattern a blind climber can read by hand.
500ft/v-aid-climbing
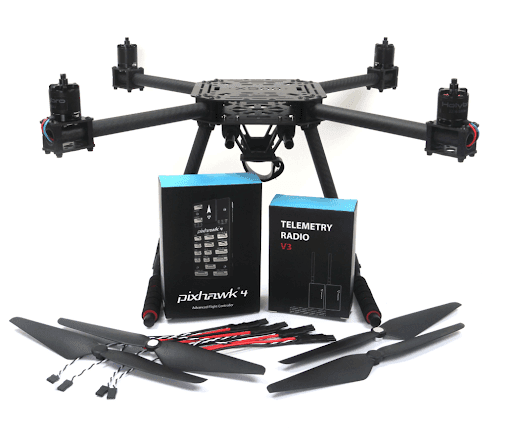
Reference image · PX4 documentation · CC BY 4.0
Tested generated C against exact and float32 references over 1.57 million randomized development steps, with no numerical-bound violations.
500ft/control-code-verification
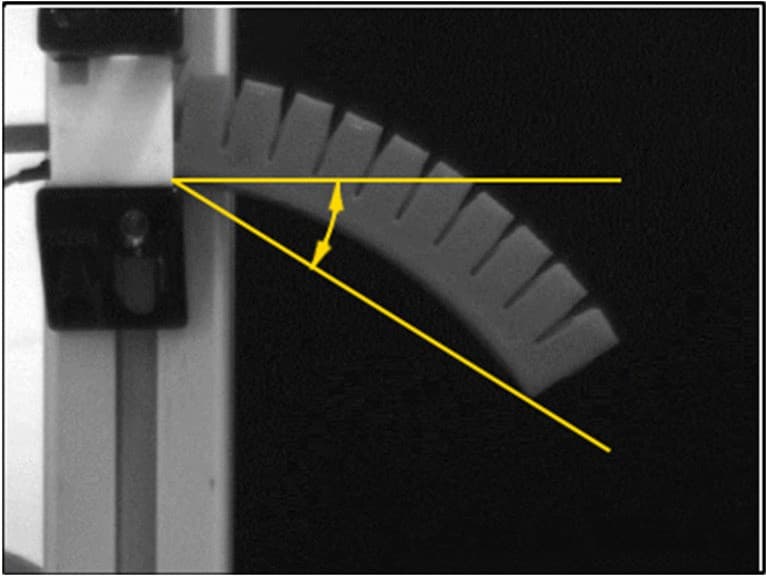
Reference image · Torzini et al. · CC BY 4.0
Built a recalibration simulation and compared pressure-volume triggers with cycle count across 20 synthetic actuators.
500ft/soft-actuator-recalibration
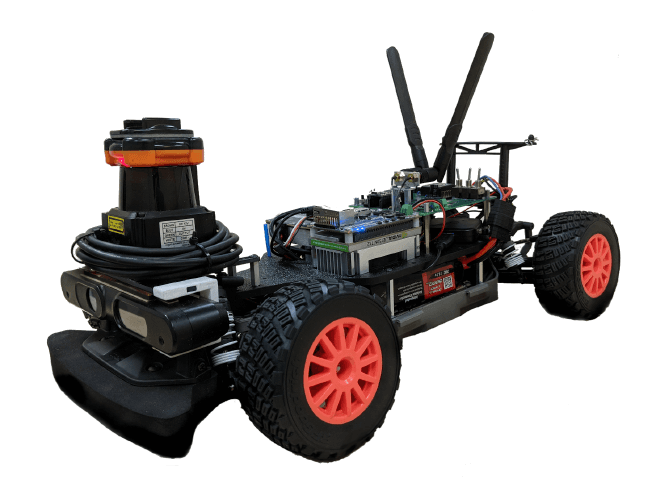
Reference image · F1TENTH Gym contributors · MIT
Qualified 15 F110 policy interfaces on synthetic cases and isolated a first-crash filtering defect, then exhaustively checked a candidate correction.
500ft/sim-to-real-controller-ranking
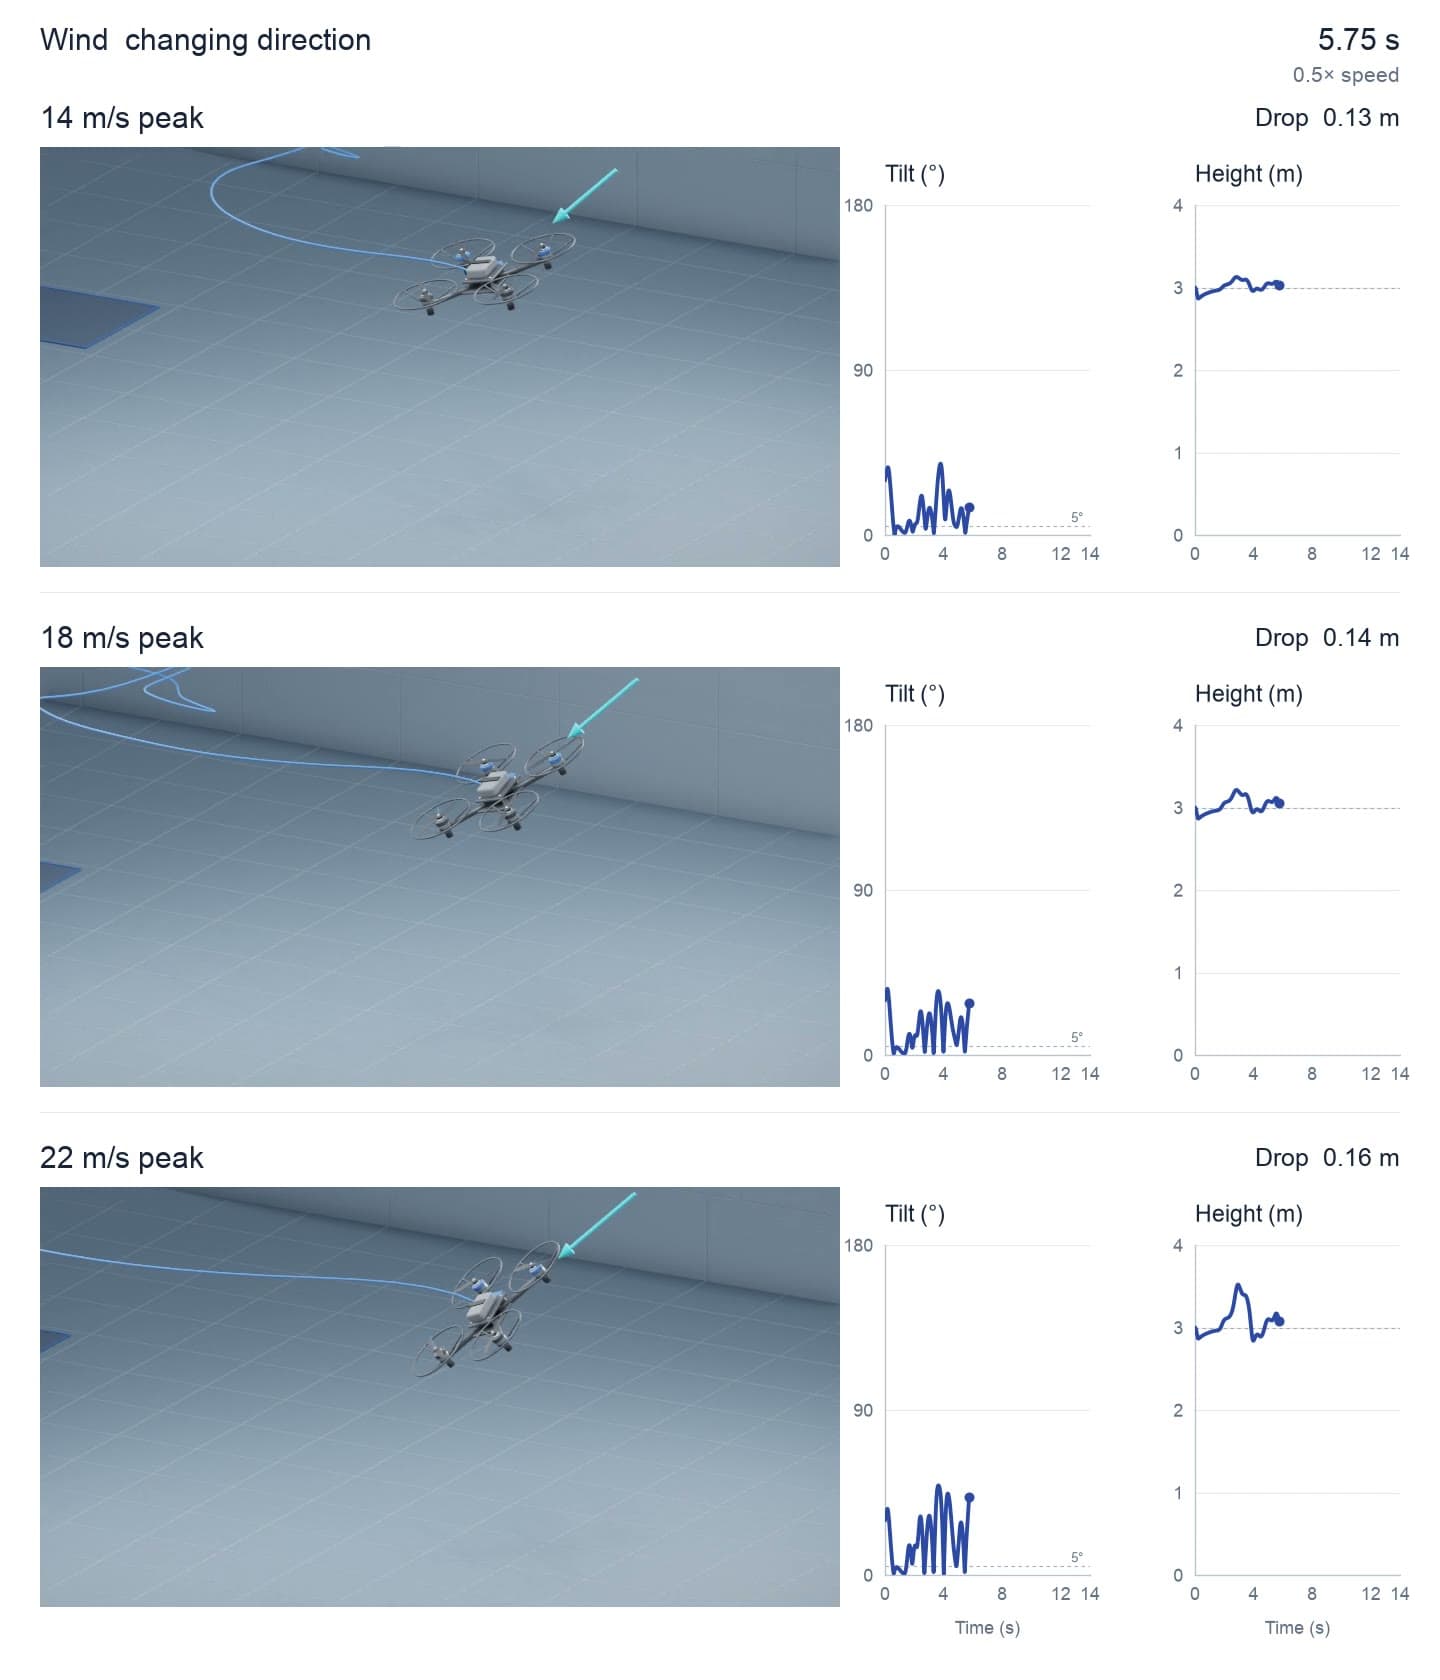
Reference image · Simulation and visualization by Mergen Ulziibayar ·
Built and visualized a drone recovery controller under changing wind, alongside a reproducible analysis of 20 altitude responses from a public QDrone2 flight.
500ft/multirotor-recovery-warning
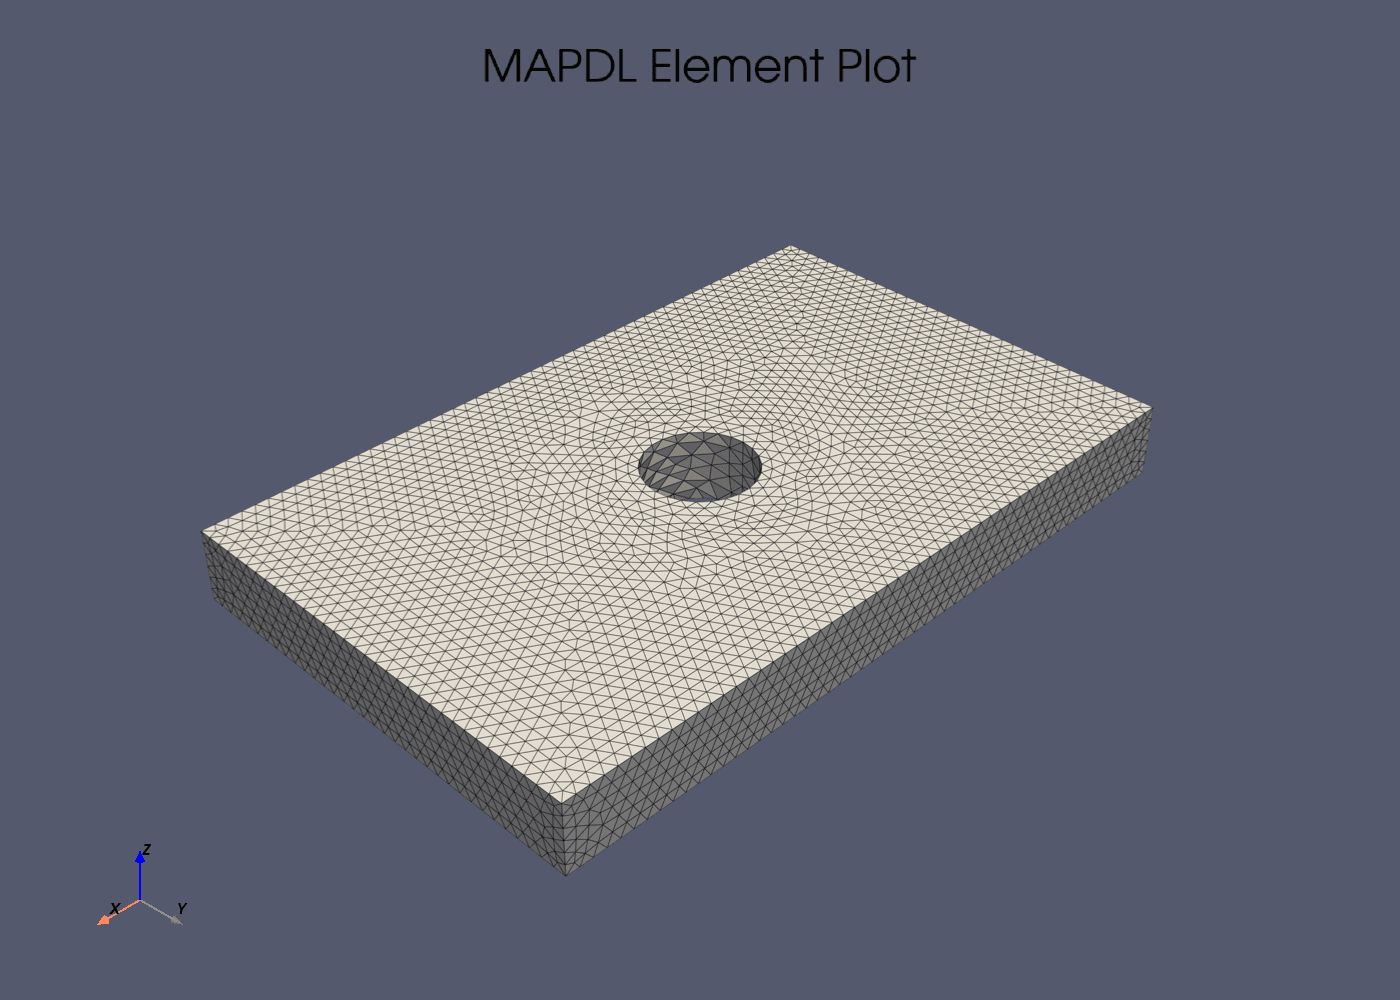
Built four scoped reference problems in mechanics and heat transfer, with separate analytical and numerical checks and an 878-variant development sweep.
500ft/evidence-sufficiency-benchmark
Reference image · NASA · NASA media usage guidelines
Verified interval shortest-path bounds, then exercised the implementation on a 32,577-node Sofala road-network fixture with synthetic travel times.
500ft/healthcare-access-uncertainty
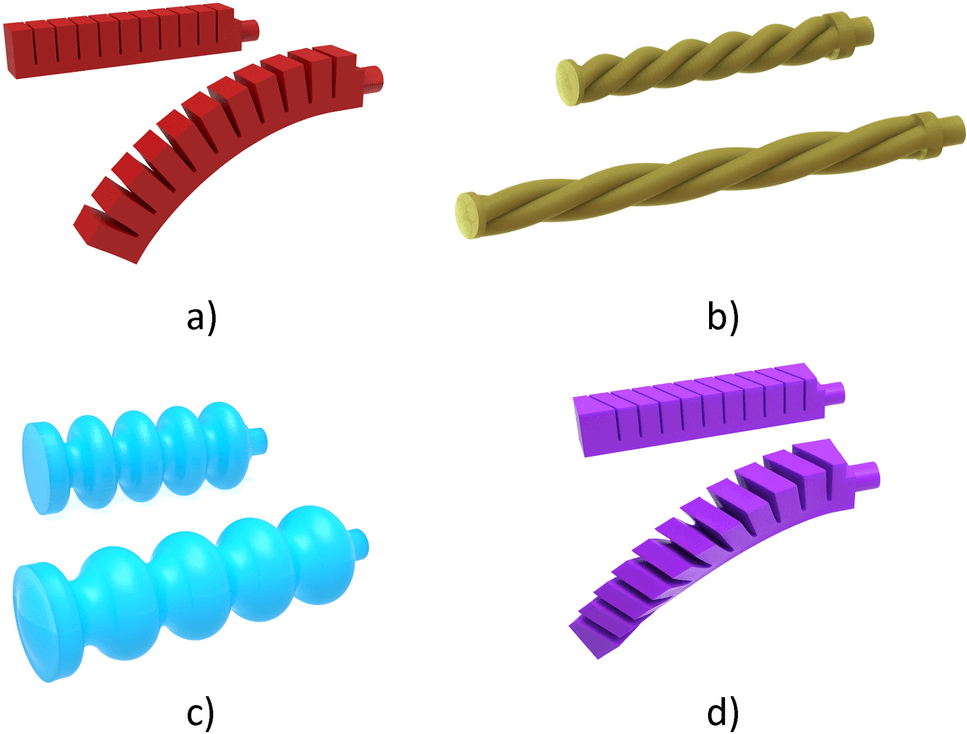
Reference image · Torzini et al. · CC BY 4.0
Developed a source-linked design brief for assistive physical interaction, connecting compliant mechanisms, force requirements and published research.
500ft/Soft-Robotic-Assistant-for-Physical-Interaction-with-Elderly-and-Rehabilitation-Patients