Soft robotic assistant
A source-linked engineering brief for a compliant assistive upper body.
Literature review and design requirements
Built a literature and requirements package for a compliant assistive upper body, with source verification, evidence grades and derived torque calculations.
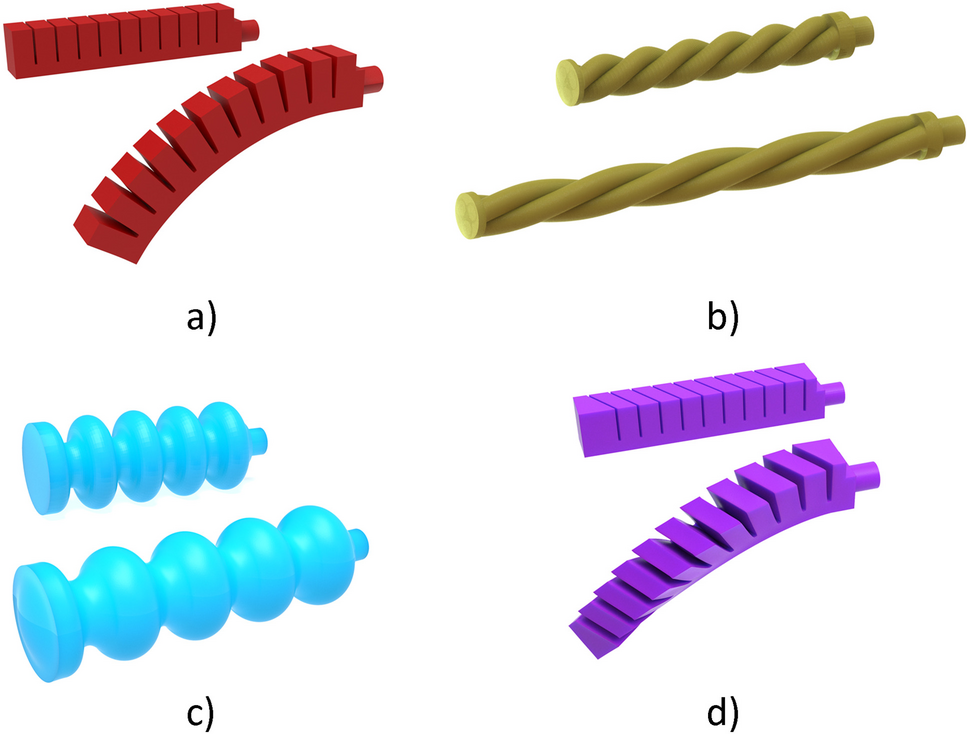
results and contributions
| Deliverable | Literature review and design requirements |
|---|---|
| Traceability | Source links, evidence grades and verification notes |
| Derived calculations | Shoulder and elbow gravity-compensation torque |
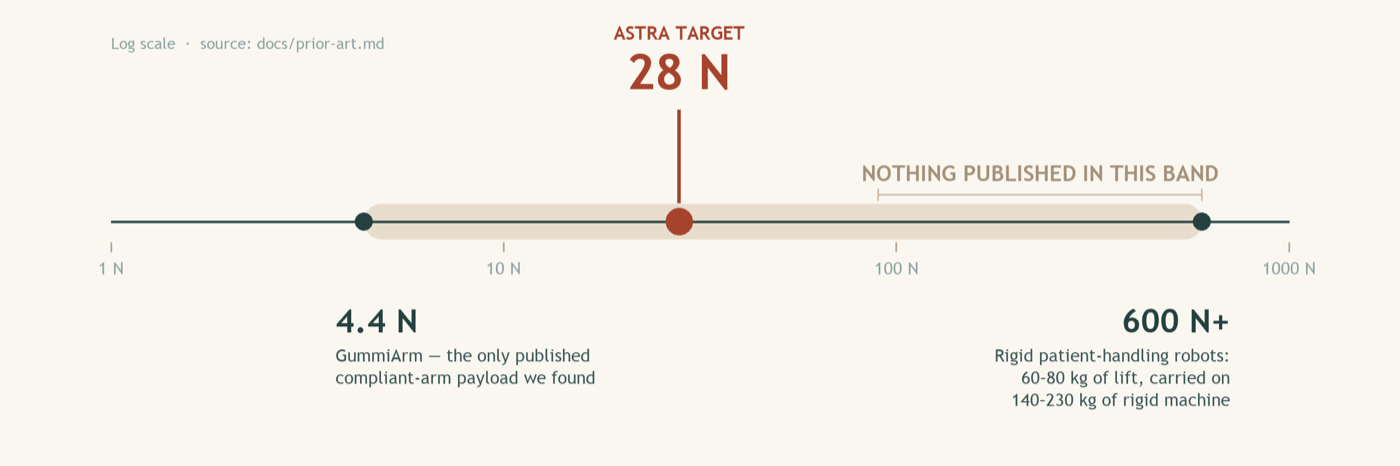
The review records each source, its evidence grade and the assumptions behind derived design values. The force comparison below connects published mechanisms to the proposed assistive role.
figures and hardware
Open any image at full size. Source links identify the retained revision.
design problem
The brief assumed that compliance is what makes contact safe and that the assistive target was tens of newton-metres. Both had to be checked before any actuator was selected, because either error sends the whole build down the wrong path.
My contribution. Designed the section structure, annotated and graded 205 sources, derived the requirements table, ran the prior-art and patent searches, and wrote the evidence boundary.
methods and scope
The requirements are derived from literature and calculations. They have not been tested on hardware or with people; the force target is a design assumption, not a patient-safety limit.
project record
| Evidence | Literature review and design requirements |
|---|---|
| Status | Concept |
| Timeline | Sep. 2026 - Present |
| Role | Literature program design, source annotation and grading, requirements derivation, prior-art and patent search, and the evidence-boundary record |
| Tools | Python, BibTeX, Literature matrix, GitHub Actions CI |